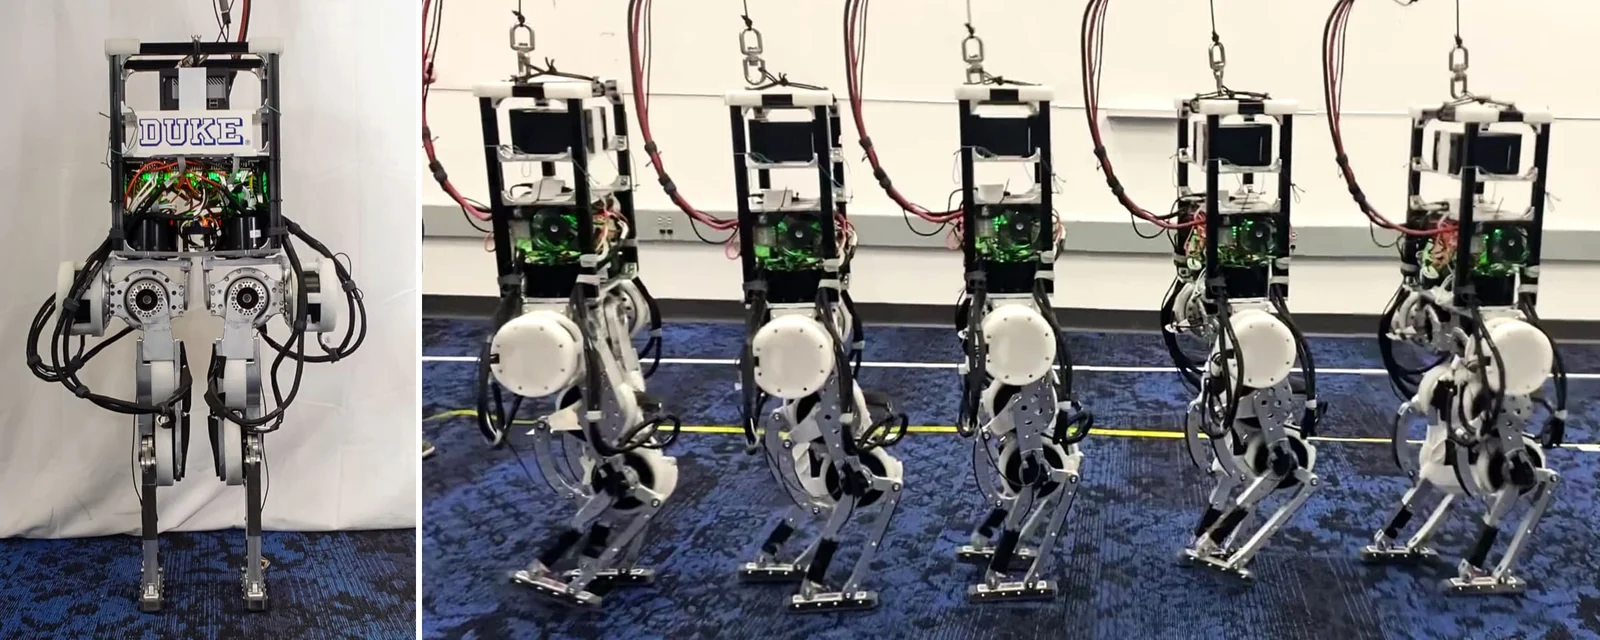
Duke Humanoid v1
Duke University General Robotics Lab · United States · Durham
crew liveL1 Compiledresearch
Open-source 10-DOF research biped for energy-efficient RL locomotion exploiting passive dynamics.

0
Verified builders
1
Labs & makers
0
Certified teams
8
Open bounties
Maintainer
Duke University General Robotics Lab
- Org
- /duke
- Signs to
- L5 Certified. Not signed yet (package is L1).
- Site
- generalroboticslab.com/DukeHumanoidv1/
- Package
- v0.1.0 · 18 steps
Find someone who has built this
Builders
Verified builders of Duke Humanoid v1
The first verified builder of Duke Humanoid v1 gets the first profile.
Build it from the v0.1.0 package, file the report with photos and bring-up logs, and this roster starts with you.
Labs
Labs and makers working on Duke Humanoid v1
| Place | Kind | City | Source |
|---|---|---|---|
| Duke University General Robotics Lab | Lab | Durham, United States | link |
Bounties
Open bounties on Duke Humanoid v1
Unfunded until a hyperspawn.org grant attaches. Each one is a gap between this robot and a finished build.
| ID | Type | Bounty | Unlocks |
|---|---|---|---|
| HB-0VPWS | Sourcing | Find China offers for 40 Duke Humanoid v1 parts | L3 Sourced |
| HB-E1G9J | Sourcing | Find Europe offers for 44 Duke Humanoid v1 parts | L3 Sourced |
| HB-ZVRPI | Sourcing | Find India offers for 44 Duke Humanoid v1 parts | L3 Sourced |
| HB-VL42P | Sourcing | Find United States offers for 13 Duke Humanoid v1 parts | L3 Sourced |
| HB-NZ3J7 | Pricing | Price 45 Duke Humanoid v1 BOM lines | L3 Sourced |
| HB-LQUIX | Assembly | Add checks and torque values to Duke Humanoid v1 assembly | L4 Built |
| HB-32M8F | Fabrication | Publish print profiles for 6 Duke Humanoid v1 parts | L4 Built |
| HB-Z1M4I | Specs | Fill 9 spec fields for Duke Humanoid v1 | Atlas accuracy |
Need help / hire a team
Ask for crew on Duke Humanoid v1.
Stuck on a step, need parts sourced, or want ten assembled. The request is logged at hyperspawn.io. Matching is done by a person until verified builders exist near you; paid jobs open once Duke Humanoid v1 reaches L5 and a team is certified.